2008年7月18日 星期五

HALE 2008 - Justin Team - building up

1. Prepare a size of 11 and 13 inch Styrofoam cake box

2. cut wholes in the middle of the two boxes with diameter 4 cm


3. make a gear that has the power of *24x36 (shown as the picture)

4. put the gear in the center of the 11” box and tape it(or and other method to connect it) with the 11” box.


5. around the 11” box, mark the circumference to 16 same sized parts

6. find a plastic folder and cut 16 pieces of the size of 14.5 cm to 2 cm


7. draw the line down the box and make a light cut threw the mark so the strips can barely fit in

8. glue or stick the strips into the indentation


9. now, fit in the smaller box into the bigger box


10. middle gearwheel will be connected to the bigger box

11. make a cape that could perfectly fit the two boxes with sealing the spaces between the two boxes


12. cut a 3.5 cm to 5 cm whole on the bigger box

13. the final processes, including connecting the NXT, putting strings on... etc.

HALE 2008 - H.A.L.E

話說接到H.A.L.E( http://www.unr.edu/nevadasat/HALE/ )任務後,便開始討論任務目的,還有酬載的運作形式
先說說任務目的吧~~經由蔡老師的努力奔走之下,終於有國內某家廠商大力贊助 SKC岀品的Stick-to-it( http://www.skcinc.com/prod/225-9808.asp ) 提供我們做為大氣垂直分段品質偵測的物件東西的樣子如下:
DSCN7308
這東西只要撕開中間咖啡色的部分就能黏著空氣中的細小微粒

有了偵測物便要開始構築機體形狀由最初的雙層夾艙式(就是林國印及黃彥閎製作的形式)
盒

再討論出盤狀式
盤
由於計算後發現體積過於龐大而作罷

所以又延伸為柱狀式的結構
柱
此結構形式也成為本次最後的形式

動作模式為中心有一旋轉的轉子由NXT控制旋轉角度,並黏上一銣硼強力磁鐵,外層則為測試玻片所在處密封方式利用軟鐵及軟性磁鐵運用磁力吸附密封,開闔由外加銣硼磁鐵與內圈轉子呈現斥性作為開啟的方式.
外
此為Space Colony No.1外層

轉子
此為Space Colony No.1內層轉子

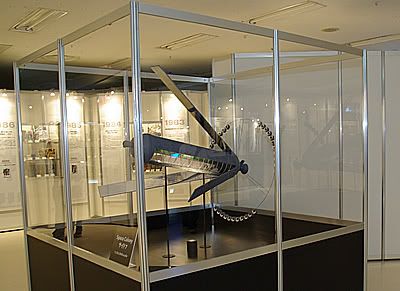
PS:為何要叫Space Colony? 因為它就長的有點像GANDAM裡的開放型宇宙殖民地 借用一下網路上的圖大家會更明白

在做完Space Colony No.1 測試之後發現許多問題,例如:轉動摩擦力過大,施工方式不易,外部機體預留太短等等..
所以在時間允許之下就有了Space Colony No.2 的誕生

因為時間所剩不多,沒有時間再做實物錯誤嘗試,所以利用多媒體軟體LightWave來做一下輔助設計的工作,
No2內
轉子部分修改的有上下加入滾珠導軌及滾珠,縮小轉子尺寸減少摩擦力,並且將磁鐵放於轉子外部以利於施工

No2外
外部隨著轉子縮小也可縮小其尺寸,並加長外部尺寸以便以後增加任務設備之需求.

有人會說為何不用工業界使用的軟體來做,因為我不會,嘿嘿~~這答案夠清楚了吧~而且多媒體有個好處做完之後可以來做個動畫無須再做轉檔的工作,輕鬆方便~~

既然模擬操作都已經完成接下還就是實做部分了~

製作型式由內而外,先做轉子部分.
轉子圓周
先利用中空板裁剪出轉子的圓周長度,並且將中空板預計在外部的那面將其中空連接的表面一一劃開但不切斷以利彎曲(這步驟相當費時費工)

轉子圓周圍上
接下來將轉子的圓面(上下各一)和剛剛的圓周長黏合

轉子上方
在上一步驟做好的轉子上下兩面上貼上滾珠導軌,各位眼尖的看官也許會發現導軌跟設計的不同,因為計劃永遠趕不上變化嘛~之前設計是分四區,但是發現如果將其貫通運作會更順暢.

轉子上方加轉軸層
接下來在導軌上貼上轉軸層,轉子旋轉就靠這層和外部圓洞作旋轉的基礎,順便也將負責開闔的磁鐵黏於圓周上.

轉子底部
將預計朝下的一面規劃出16等分,將其貼上黑與白膠帶以便區分角度,並將負責動力的齒輪固定上去.

外層合體
將16邊形桶狀外部做出,並且將轉子放入,放入時要記得將兩面的滾珠導軌中放入滾珠.

07
將轉子底部滾珠層覆蓋後並在此層加入動力設備

動力近拍
動力設備近攝~~

08
與外層結合狀況

09
放正時之模樣

10
外部開闔磁鐵黏貼方式

掀板
掀板以及密合區

2008年7月16日 星期三

H.A.L.E. Payload Preparation Istructions (Draft)

1. Let the bottom of the payload face up
2. Tear off the black tape
3. Open the petals
4. Remove the “Bottom” board
5. Pull out the foam from the place where it says “PULL me
6. Remove the NXT from its compartment
7. Place in batteries in the NXT
8. Now, connect the wire A to NXT output A (wires are labeled)
9. Connect Wire “2” to NXT input 2
10. Turn on the NXT
>Go into “My Files”
>Go into “Software Files”
>Go into the file “HALE-TW”
>Run the file
11. Connect Wire “1” to NXT input 1
12. Place the NXT back into it’s compartment
13. Place eight AA batteries into the battery pack
14. Connect the battery pack with the black box (camera)
15. Place the bottom foam back into the payload (match the marking)
16. Place the bottom board back into the payload
17. Close the bottom with black tapes as shown as the pictures
18. Make the payload’s top facing up
19. Connect the green strings to the main balloon strings
20. Press the button twice right before the payload is up in the air

2008年7月11日 星期五

HALE 2008 - 銘傳大學實驗組

各位大家好!
我們是銘傳大學的學生
以下是我們做的機器人以及一些圖片
就由我來先做一些簡介


這個是我們的機器人模型

我們的構想是用機器人的手臂去推動盒子(或木頭)

讓裝了載玻片的盒子可以出去採集

它的手臂可以轉動

也可以藉由上面吊的線來上下移動

設計放載玻片的盒子式直立式的

所以會需要上下移動


這個是設計放載玻片的盒子

中間那可以轉動的地方會放入載玻片

經由機器人的手臂去推動它之後會跑出去收集

等到設定的時間到了之後會經由手臂再推回來


以上是我目前所做的簡介
之後的會陸續放上

2008年7月10日 星期四

HALE 2008 - **IMPORTANT** from Justin

our group, the high school group, has decided to use the new technique. the one that is recently updated is the one we are working on. The other machine that was post ago isn't as good as the new one, so we decided to replace the old one. Don't get confused


-Justin Lin reminds you

HALE 2008 - feelings and difficulties

hey guys, bad news, we got only a week to put our robots up in the air

in our Taiwan team, we split to 3 groups, temporarily.

-six college students (MingChuan University)
-two high school students (Justin Kou Ing Lin, Taipei American School / David Huang, Taipei Municipal Jianguo High School)
-Professional Engineer/teacher(Mr. Chou)

as the whole team, our goal is to send a auto machine to take samples up in the air.
our high school group designed is shown as the picture below


we have two layers of cake styrofoam that is connected by a turning point. the motor in the middle is connected to the top layer, which will be turning the lower layer. We have sixteen individual sealed rooms which each will hold a sample taking tape. There will be a small whole on the outer layer of the cake box so whenever the outer layer is turned to, one out of the sixteen rooms will be exposed to outer air to take sample.


each group from our team has distinctive designs, which we, as a team, will choose the best one to send up in the air.
for our group, the high school team, we faced many challenges. The most obvious challenge for us is the resources and technology we have. Don't even talk about a professional engineer, even college students have their own labs and advance equipments. We only have common tools and our hands. Consequently, we faced inaccurate measurements and incisions.
Secondarily, we need to make sure each individual room is absolutely isolated because we don't want the elements that was taken on each sample to spread throughout the sixteen rooms. there will be no point of making sixteen rooms if that happens. Since the outer layer is turning around the the inner layer of the cake box, there must be some tiny crack at the common boundary connecting the inner layer and outer layer. that tiny crack is enough to let elements from each room to spread around. One of our solution is to use a special material, silica gel. Since the material is flexible, we will use that to be the doors that isolate each room. The silica gel will scrape on the outer layer to make sure each room's dust is kept within it's own space.(the silica gel will be attached on the inner layer.) however, the silica gel will increase the resistance that the motor will have to overwhelm it. we still have to test the motor's strength and find a way to decrease that resistance as much as possible.
Our final task, if every problem above is solved, will be how flinty our compartment should be when it plonks(fails) from 33,000 meters above the ground and all are rooms are still contaminated.

This is a rare and interesting project for us. WISH EVERYONE IN THE TEAM "GOOD LUCK!!"


-Justin Lin

2008年7月1日 星期二

HALE 2008 - 會議

2008/6/30 蔡宇振老師(左一)與周克宇老師(左二),討論Spider Team林國印(右一)、黃彥閎(右二)所製作的酬載原型。

Spider Team試做的原型是八爪結構(類似蜘蛛的八隻腳),每隻腳的末端推動一片捕捉板。


利用兩顆馬達:A馬達轉動捕捉板,將捕捉板暴露在空氣中;B馬達轉動A馬達轉,讓A馬達可以分別轉到每隻腳的位置,一次打開一片捕捉板。

A馬達以齒輪轉動捕捉板的方式有缺點,將測試使用輪子轉動捕捉板的方式。